Presenting Ask-to-Act at IEEE RO-MAN 2026 in Japan
· 2 min read · 0 views
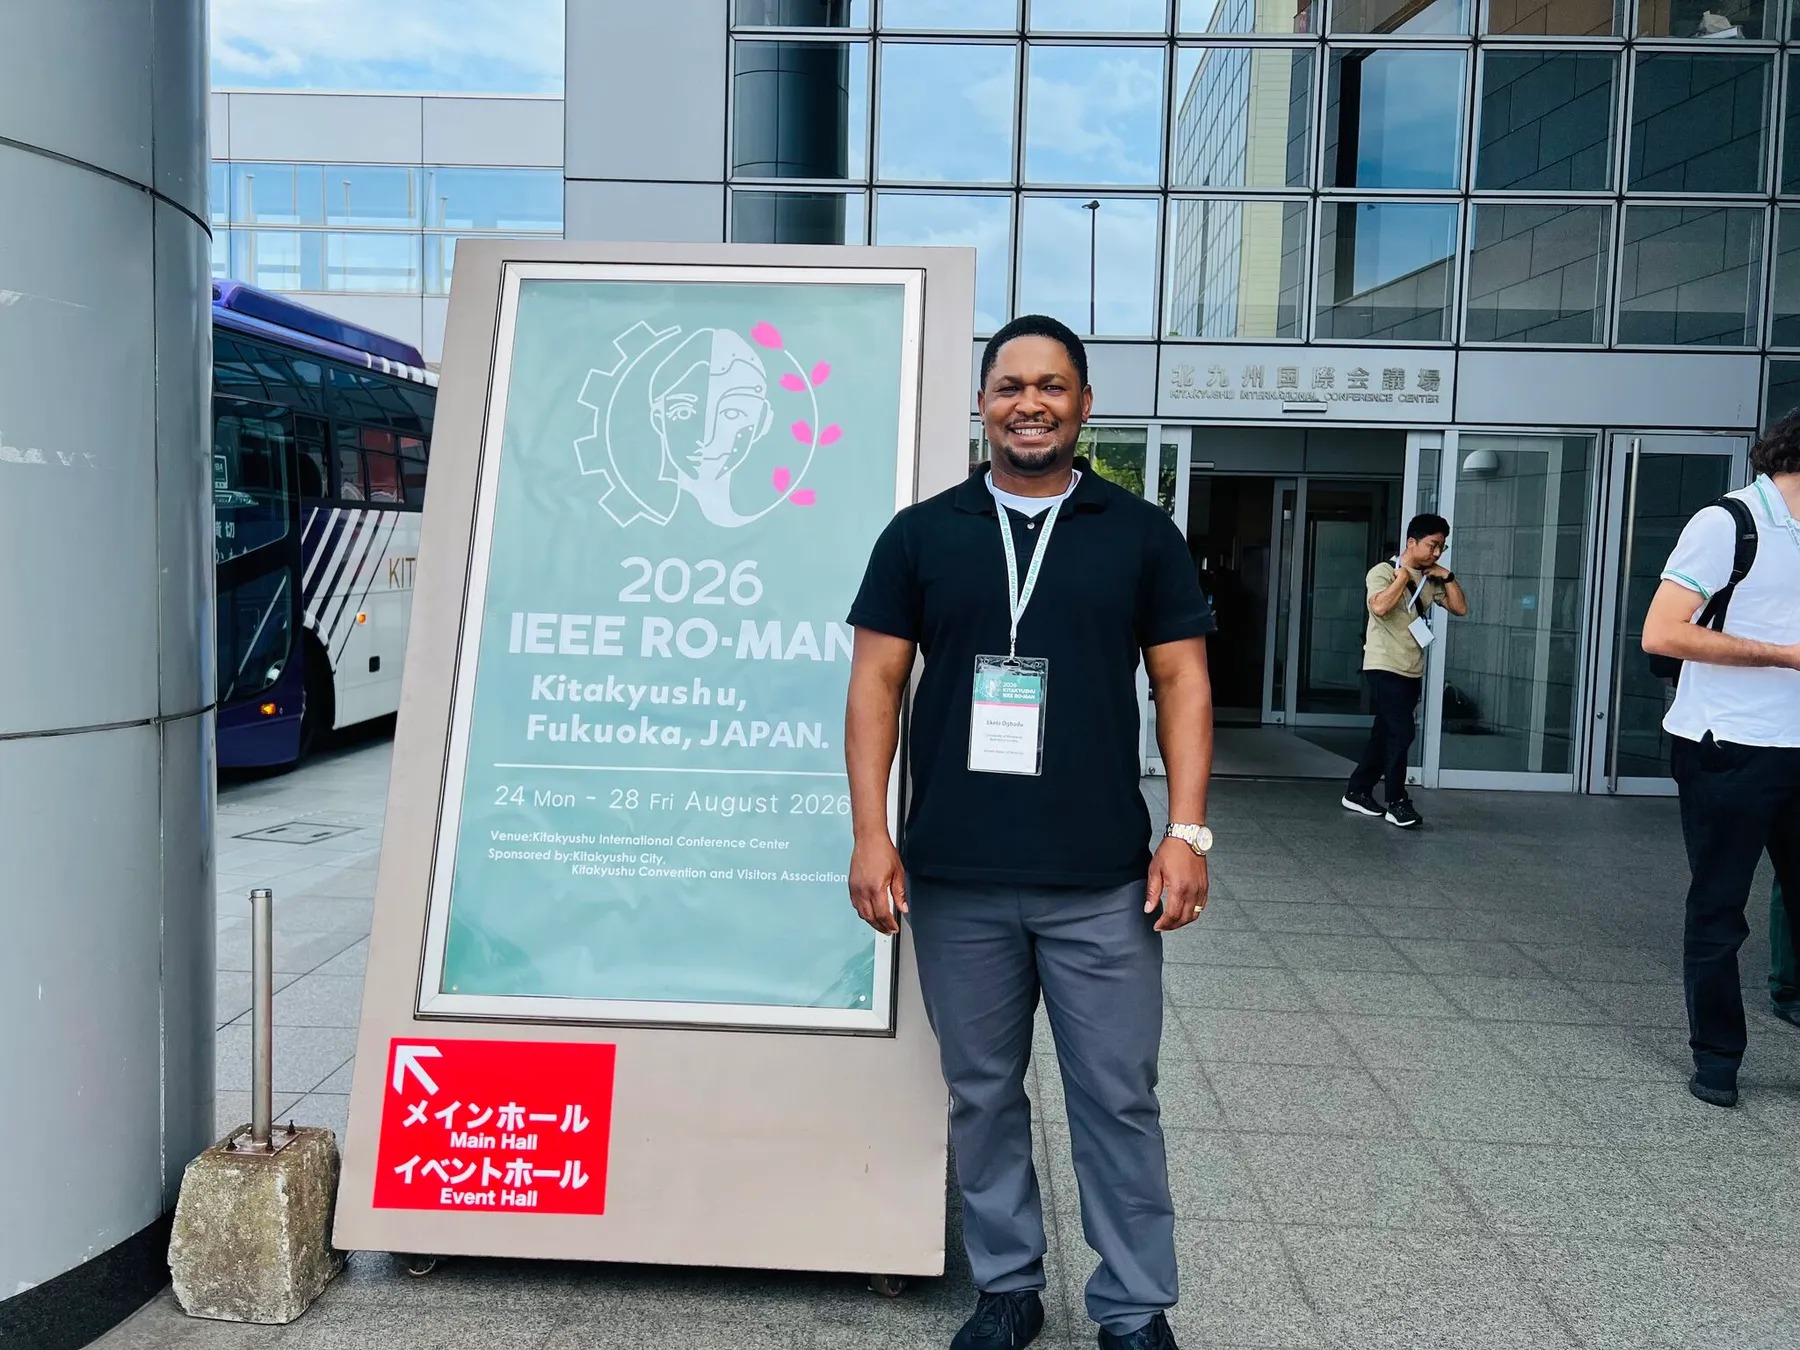
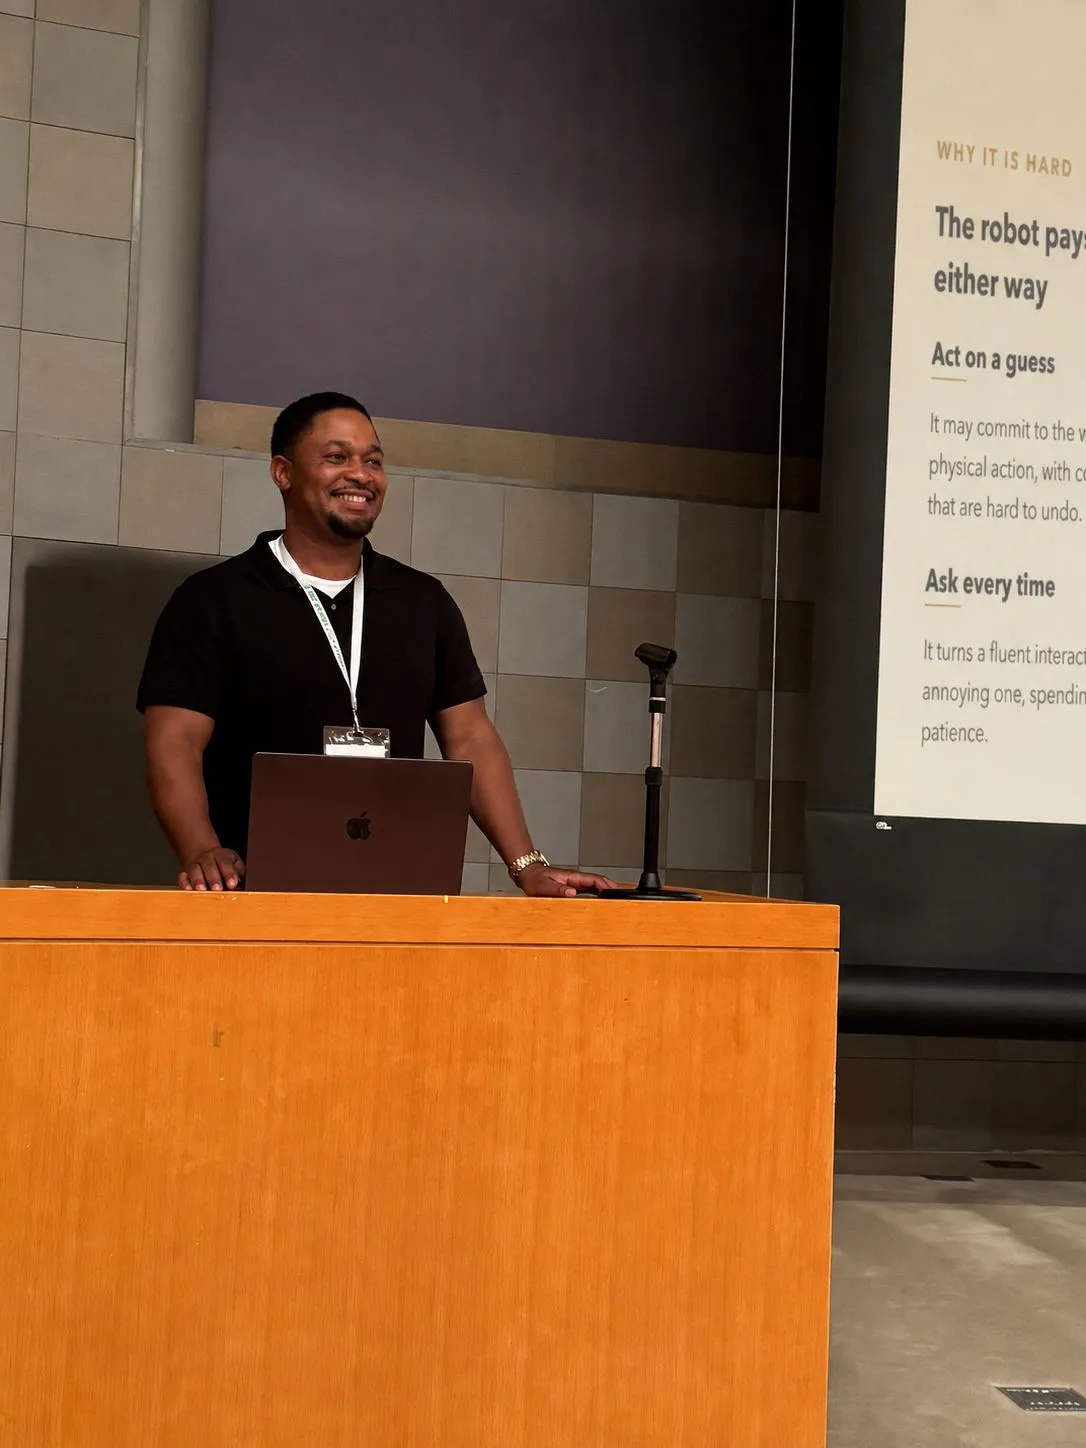
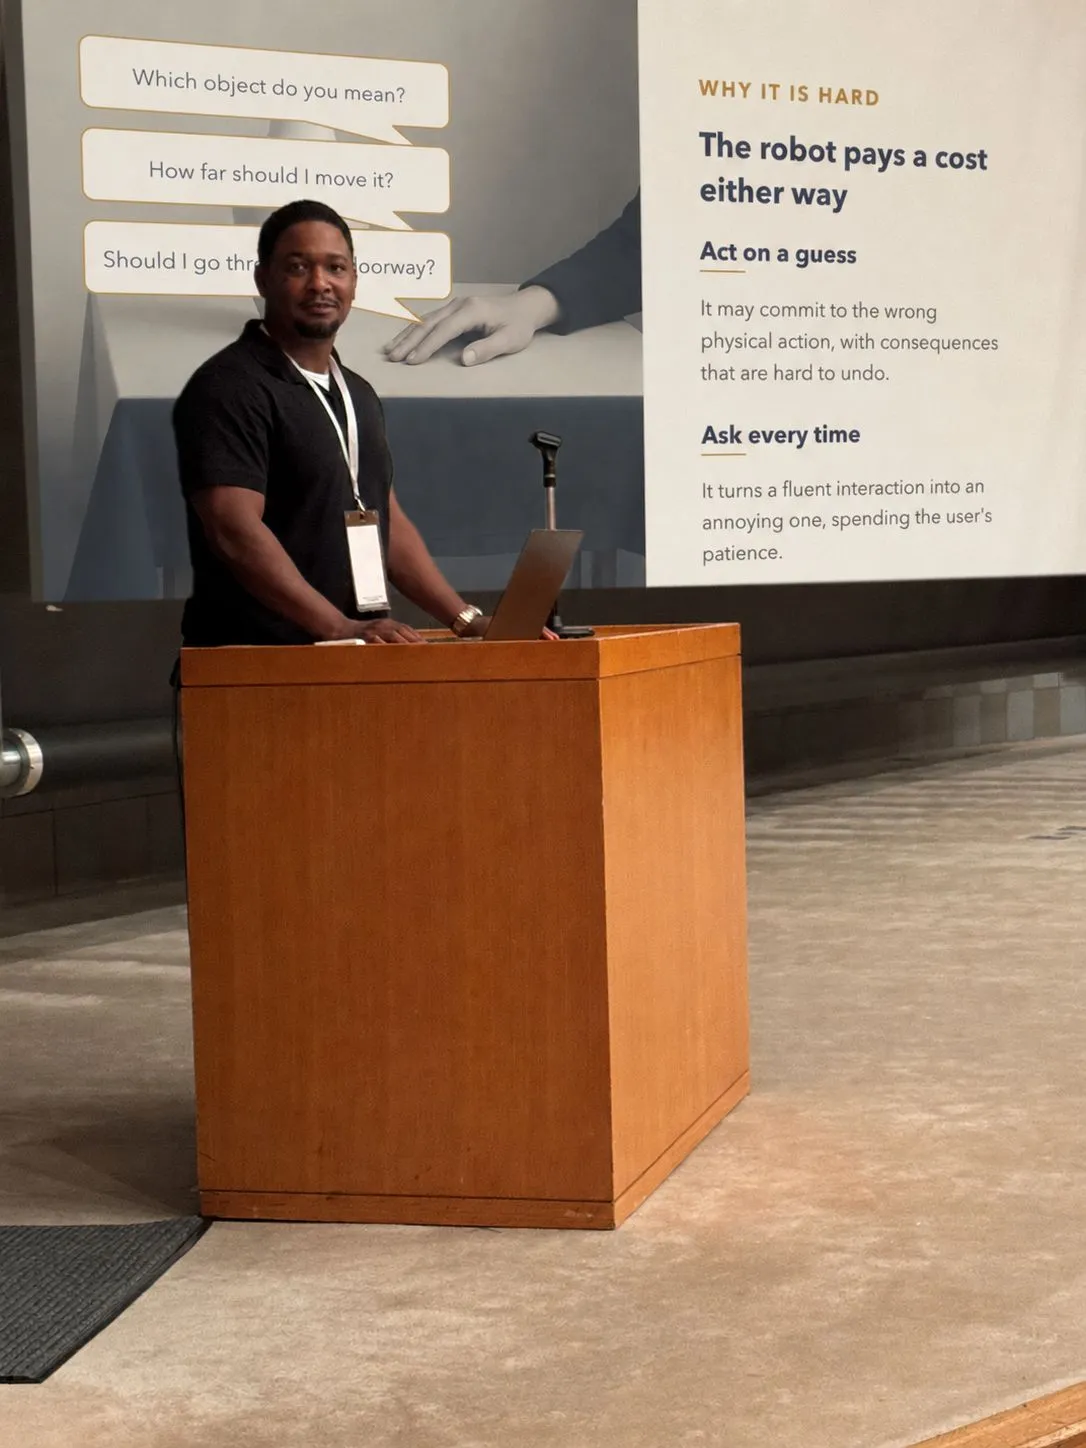
Last month, I traveled to Kitakyushu, Japan, to present my first-author paper (Ask-to-Act: Learning When Robots Should Clarify Ambiguous Grounded Instructions) at IEEE RO-MAN 2026. It wasn’t my first time in Japan or my first time presenting at a conference, but the experience was so much fun that it felt like I was doing both for the first time.
I also got to present three papers on behalf of my colleagues in the Interactive Robotics and Language Lab at the University of Maryland, Baltimore County. That made for a busy conference, but as you can imagine, I was never bored.
I should mention that my research looks at what a robot should do when someone gives it an instruction that could mean more than one thing. If the robot guesses, it may take the wrong action. But if it stops to ask a question every time, it quickly becomes frustrating to work with.
My aim was to figure out how a robot could decide when it has enough information to act and when it should ask for clarification first.
This is the direction I want to continue pursuing: robots that can follow instructions while also recognizing when they need more information to complete an assigned task.
I’m currently spending my weekends getting the repository ready to make public. I’ll share the repository and a link to the paper on my profile shortly for anyone interested in reading more.
It was rewarding to share the work, answer questions, and meet researchers working on similar problems from around the world. I’m grateful to my co-authors, advisor, and everyone who helped make the paper and this experience possible.
And while I got a lot of good work done while I was in Japan (which I’ll be posting about in the coming days), getting to experience more of the Land of the Rising Sun along the way made the trip even more memorable.
Originally posted on LinkedIn.